
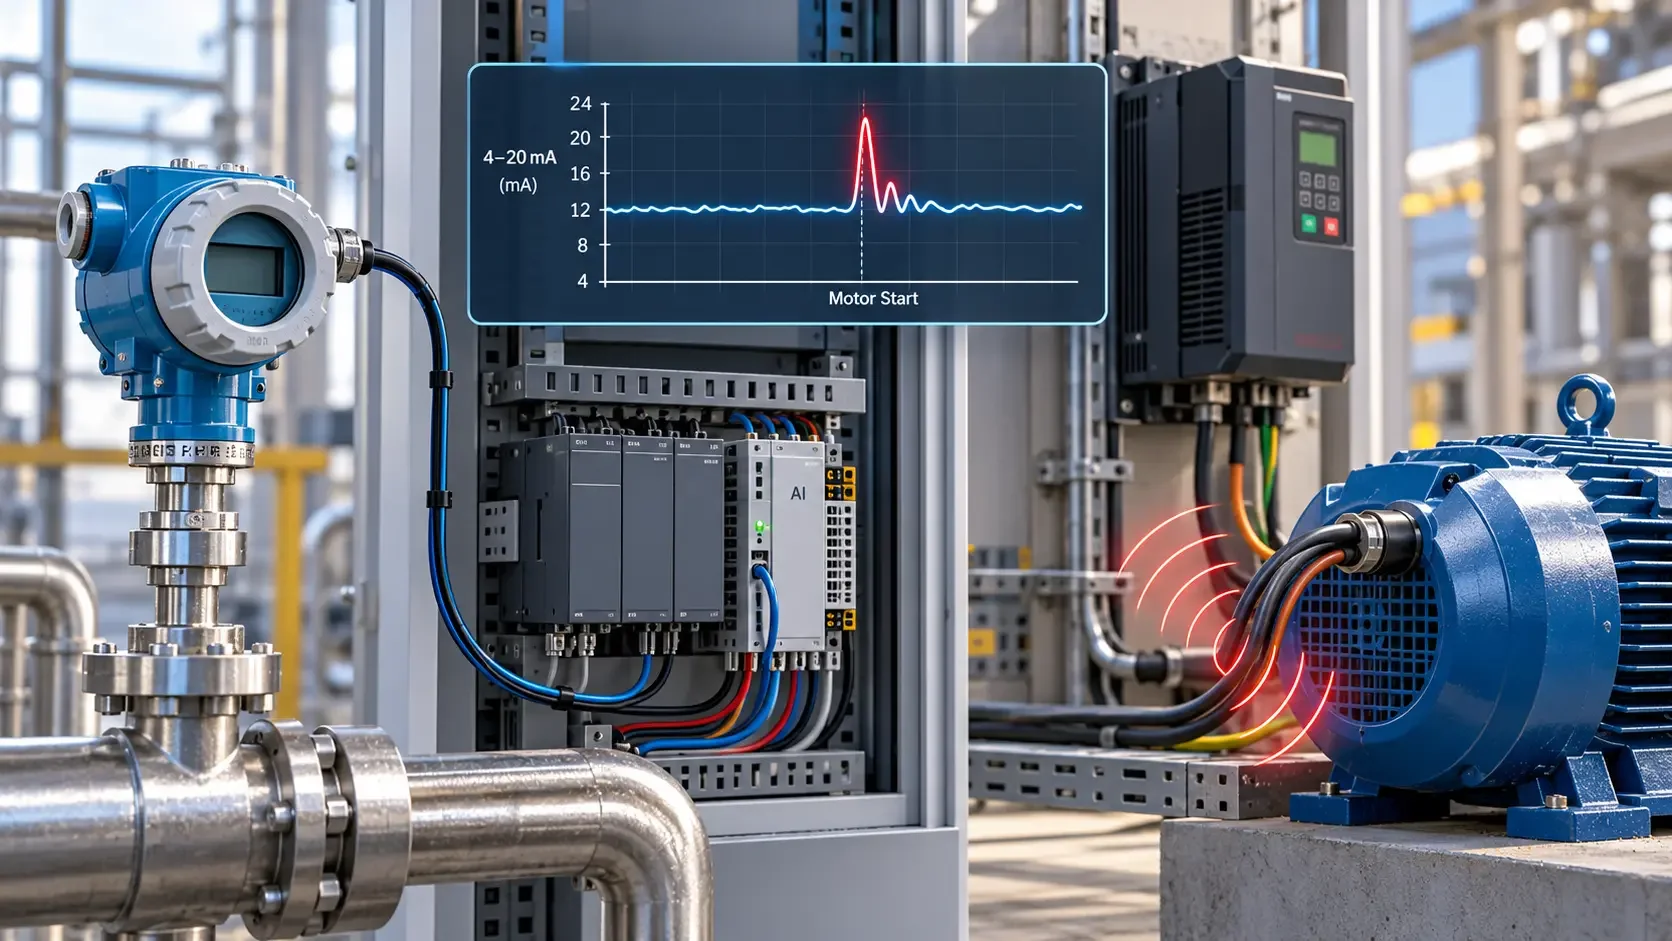
# Why Does a 4–20 mA Signal Jump When a Motor Starts?
A practical engineering guide to diagnosing unstable analog signals, VFD interference, grounding problems, and hidden control-system faults.
By Veselin Madzharov
A pressure transmitter works perfectly for hours. The PLC displays a stable value, the machine operates normally, and the operator has no complaints.
Then a large motor starts.
For a fraction of a second, the pressure reading jumps. The PLC records an abnormal value, an alarm appears, or a control sequence reacts to a condition that never actually occurred.
The maintenance team replaces the pressure transmitter.
Nothing changes.
A second transmitter is installed. The fault remains.
The problem was never necessarily the sensor. It may have been somewhere between the transmitter, its power supply, the signal cable, the analog input module, and the electrical environment surrounding the machine.
This is why intermittent 4–20 mA faults are among the more deceptive problems in industrial automation.
1. Why a current signal can still be disturbed
The 4–20 mA interface is widely used because a current signal is relatively resistant to voltage drops along a cable.
Unlike a simple voltage-output sensor, a properly operating current-loop transmitter regulates the current representing the measured process variable.
For a linear transmitter:
I = 4 + 16 × (PV − LRV) / (URV − LRV)
Where:
- I = loop current in milliamperes
- PV = measured process value
- LRV = lower range value
- URV = upper range value
Consider a pressure transmitter configured for 0–10 bar.
| Pressure | Signal |
|---|---|
| 0 bar | 4 mA |
| 2.5 bar | 8 mA |
| 5 bar | 12 mA |
| 7.5 bar | 16 mA |
| 10 bar | 20 mA |
At 5 bar, the expected output is 12 mA.
If the PLC suddenly displays 7.5 bar while the actual pressure remains 5 bar, the displayed engineering value has changed by 50% of the expected 5-bar reading.
That does not automatically mean the transmitter has produced 16 mA. A disturbance may also exist in the analog input electronics, conversion logic, scaling, or signal-processing system.
The first diagnostic question is not whether the sensor has failed. It is where the incorrect information first appears.
Current loops are robust, not immune. Common-mode interference, inadequate voltage headroom, unintended ground paths, damaged connections, and receiving-module problems can still produce incorrect measurements.
2. What changes electrically when a motor starts?
Motor starting can affect a control system through several different mechanisms.
A direct-on-line motor can create a substantial starting current, potentially producing a temporary voltage reduction in a weak or heavily loaded electrical distribution system.
A variable-frequency drive introduces another category of disturbance: fast semiconductor switching, high-frequency common-mode currents, and electromagnetic coupling into nearby wiring.
These mechanisms are not identical, and they should not be diagnosed as though they were.
Supply voltage disturbance
A motor-starting event may coincide with a reduction in the voltage available to control equipment.
If a transmitter or its supporting power supply loses adequate operating voltage, its current output may become unstable or leave its normal operating range.
Electromagnetic interference
VFD motor cables can generate significant electromagnetic interference because of rapid voltage transitions.
Signal wiring routed close to such cables may experience coupled disturbances, particularly when the installation has inadequate cable separation, unsuitable shielding, or poor bonding practices.
Unintended reference paths
Non-isolated interfaces can allow unwanted current paths between equipment operating at different electrical potentials.
A disturbance that appears when a drive operates may reflect a grounding or common-mode problem rather than a damaged transmitter.
Analog input disturbance
Even when the field signal is nominally correct, the receiving equipment may be affected by common-mode voltage, an input-stage problem, or an unsuitable measurement configuration.
The PLC's reported engineering value is the end of a measurement chain, not direct proof of the physical process.
3. The diagnostic evidence that matters
An intermittent analog fault should be investigated as a relationship between events, not as an isolated number on an HMI.
The useful questions are:
- Does the abnormal reading coincide with motor acceleration, drive switching, or another electrical event?
- Is the physical process actually changing?
- Do multiple analog channels show disturbances at the same time?
- Does the PLC's raw input value change, or only the displayed engineering value?
- Does the transmitter report a diagnostic alarm?
- Is the disturbance present continuously while the motor runs, or only during transitions?
These observations help distinguish several different failure mechanisms.
| Observed symptom | Possible explanation | Important distinction |
|---|---|---|
| Brief spike during VFD acceleration | Electromagnetic coupling or transient disturbance | Confirm whether the physical variable also changes |
| Several sensors fluctuate together | Shared supply, reference, or input-module problem | Look for a common dependency |
| Reading becomes unstable at high process values | Insufficient loop voltage headroom | Load resistance becomes more significant at higher current |
| PLC value changes while an independent process indication remains stable | Measurement-chain or scaling problem | Determine where the disagreement begins |
| Signal changes with equipment vibration | Intermittent connection or cable damage | Correlation with vibration is not proof of EMI |
| Reading remains wrong after the motor stops | Configuration, latched fault, or persistent hardware condition | Examine diagnostics before resetting anything |
No single symptom proves a particular root cause.
A motor-starting event can reveal a problem that was already present in the installation.
4. Understand the loop voltage budget
A 4–20 mA transmitter needs sufficient voltage to regulate its output current across the connected load.
The available supply voltage must cover the transmitter's minimum operating requirement and all other voltage drops in the loop.
For a simplified two-wire loop:
V_supply ≥ V_transmitter_min + I × R_total
Here, R_total includes the applicable receiving-input burden, wiring resistance, and other series elements.
Consider an illustrative system with:
- 24 V DC nominal supply
- 12 V minimum transmitter operating voltage
- 250 Ω analog input burden
- 1 V allowance for remaining series voltage drops at full-scale current
At 20 mA, the 250 Ω receiving input produces:
V_input = 0.020 A × 250 Ω = 5 V
The nominal remaining voltage margin is:
24 − 12 − 5 − 1 = 6 V
This example leaves 6 V of headroom at nominal supply voltage.
However, if the available supply decreases, that margin also decreases. Any additional series device, excessive wiring resistance, or higher-than-expected transmitter requirement reduces it further.
At sufficiently low available voltage, the transmitter can no longer maintain the intended current.
This effect is especially relevant when a loop works normally at low output current but fails near the upper end of its measurement range.
The actual calculation must use the relevant equipment datasheets, supply tolerances, and installation conditions. The numbers above are illustrative rather than universal equipment ratings.
5. A realistic factory fault: the pressure spike that never happened
Consider a packaging machine with a pressure transmitter connected to a PLC analog input.
The transmitter measures 0–10 bar using a 4–20 mA output.
Under normal conditions, the process pressure is approximately 5 bar.
A VFD-controlled conveyor motor starts several times per minute.
Each time the drive accelerates, the HMI occasionally displays a short pressure spike reaching approximately 7.5 bar.
The PLC logs the corresponding increase in its raw analog input value.
However, an independent mechanical pressure indicator remains near 5 bar, and the transmitter's local process indication does not report the same increase.
The process therefore appears stable while the electrical measurement chain reports a disturbance.
The misleading first diagnosis
Because the alarm identifies a pressure problem, the transmitter becomes the first suspected component.
Replacing it seems reasonable.
But a new transmitter produces the same symptom.
The evidence now points toward a shared installation condition, signal path, or receiving system.
Finding the common factor
A review of the wiring documentation reveals that the analog signal cable follows a section of the VFD motor-cable route.
Further examination by qualified personnel identifies an installation arrangement that does not meet the applicable cable-separation and shielding requirements.
The installation is corrected according to the equipment manufacturers' EMC guidance.
Subsequent recorded production cycles show stable analog values through repeated motor starts.
This is an illustrative diagnostic case, not a documented incident from a particular factory.
The lesson is not that every unexplained pressure spike comes from a VFD. It is that event correlation, independent process evidence, and a review of the complete signal path can prevent unnecessary sensor replacement.
6. Shielding and grounding: the details matter
One frequently repeated rule says that every analog cable shield must be connected to earth at one end only.
That rule is too simplistic.
The correct arrangement depends on the system design, signal interface, interference frequency, galvanic isolation, equipotential bonding, and manufacturer requirements.
In some instrumentation arrangements, single-ended shield termination is appropriate for limiting low-frequency circulating currents.
In other industrial EMC installations, a properly designed high-frequency bonding arrangement or shield termination at both ends may be necessary.
The objective is not to follow a universal slogan. It is to provide the intended interference-current path without introducing unacceptable disturbances into the measurement system.
The distinction is particularly important in installations containing variable-frequency drives.
A disconnected shield is not automatically a solution to a grounding problem. An additional grounding connection is not automatically an improvement either.
Signal cable separation, appropriate shielding, equipotential bonding, and interface isolation must be considered as parts of one design.
7. Electrical interference or a real process change?
Sometimes the apparent interference is not interference at all.
A large motor starting may cause a genuine process disturbance.
For example, a pump may change pressure, a compressor may alter air demand, or a shared electrical supply may affect another actuator.
A transmitter responding to these physical changes is operating correctly.
The practical distinction is between three different events:
Event A — The process changes.
The transmitter reports a genuine variation.
Event B — The process remains stable, but the electrical signal becomes disturbed.
The measurement circuit requires investigation.
Event C — The process and field signal remain stable, but the PLC or HMI displays an incorrect value.
The receiving input, scaling, data processing, or communication path becomes the focus.
These events can produce similar operator complaints while requiring completely different corrective actions.
Independent observations and historical trends are therefore valuable diagnostic evidence.
8. Why increasing the PLC filter is not always a repair
Analog input modules often provide filtering, averaging, or integration settings.
Increasing filtering can reduce the visibility of brief disturbances.
That does not necessarily remove their cause.
Excessive filtering also introduces measurement delay.
In a slow temperature-monitoring application, a modest additional delay may be acceptable.
In a fast pressure-control or motion-related application, the same delay could affect response, alarm behavior, or control stability.
Filtering must therefore be evaluated against the process dynamics and control requirements.
A noisy signal should not simply be hidden until the display looks stable.
A stable display is not proof of an accurate measurement.
9. A systematic diagnostic workflow
An effective engineering investigation preserves evidence and separates competing explanations.
The following sequence is intended as a diagnostic framework for qualified maintenance and automation personnel.
Stage 1 — Establish the expected behavior
Document the transmitter range, process variable, loop type, nominal supply, input configuration, and intended signal scaling.
Identify whether the measurement is part of monitoring, closed-loop control, alarming, or a safety-related function.
Stage 2 — Capture the event
Use available PLC diagnostics, historical trends, equipment event logs, and independent process indications to determine the timing and extent of the disturbance.
Record relevant motor and drive operating states.
Stage 3 — Identify common dependencies
Review whether affected channels share a power supply, analog input module, reference connection, cable route, or installation environment.
A common disturbance across several channels is particularly valuable evidence.
Stage 4 — Evaluate the engineering documentation
Review the loop voltage budget, equipment specifications, isolation arrangements, cable routing, shielding requirements, and relevant EMC installation instructions.
Stage 5 — Plan approved technical verification
Any intrusive electrical inspection or measurement must be performed by appropriately qualified personnel under the machine's approved safe-work procedure.
Use suitable isolation and energy-control methods before opening circuits or altering wiring. Electrical hazards and stored energy can remain present even when a machine has stopped.
Stage 6 — Verify the corrective action
After an identified defect has been corrected and the system has been returned to service through an approved procedure, compare the recorded signal behavior under the same operating conditions.
The result should demonstrate that the original disturbance has been eliminated without creating a new control or measurement problem.
10. Common mistakes in 4–20 mA troubleshooting
Several habits make intermittent analog problems more expensive than necessary.
Replacing the transmitter immediately.
The transmitter is only one part of the measurement system.
Assuming every disturbance is electromagnetic interference.
A genuine process transient or a supply-voltage problem can produce similar symptoms.
Ignoring the analog input configuration.
Incorrect range selection or scaling can turn valid electrical data into an incorrect engineering value.
Treating all shield connections identically.
Shield termination must follow the actual system and manufacturer requirements.
Increasing filtering without considering process response.
A smoother trend may conceal the symptom without eliminating the defect.
Closing the maintenance case after one successful cycle.
Intermittent faults require verification under the operating conditions that originally produced them.
Technical conclusion
A 4–20 mA signal does not become unreliable simply because a motor starts.
Something changes in the process, the supply system, the electromagnetic environment, or the measurement chain.
The most effective diagnostic method is to determine which change occurred and where incorrect information first entered the system.
An apparent pressure fault may be an analog input problem. A suspected transmitter failure may be a shared power-supply issue. A presumed interference problem may actually be a genuine pressure transient.
The objective is not to replace the component named by the alarm.
The objective is to prove the physical cause, correct the installation or equipment defect, and verify that the measurement remains reliable under real operating conditions.
Further Reading — Recommended Engineering Books
For a deeper understanding of industrial sensor interfaces, analog measurements, wiring problems, PLC inputs, and systematic fault diagnosis, explore these technical guides by Veselin Madzharov.
Industrial Sensor Wiring and Troubleshooting
Covers PNP/NPN sensor circuits, analog signals, wiring faults, voltage drop, grounding, electrical interference, and real industrial troubleshooting.
Industrial Sensors in Automation Systems
Explains how field measurements interact with PLC systems, remote I/O, industrial networks, signal processing, and modern sensor diagnostics.
Industrial Electrical Panel Diagnostics
Examines intermittent faults, control power, PLC I/O, signal integrity, grounding, and electrical panel reliability.
Independent technical engineering books for professionals who prefer evidence-based troubleshooting over guesswork.


